Robot tool changers
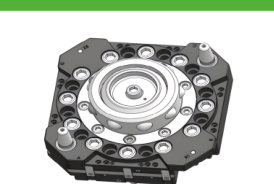
AQC-550 Automatic robot tool changer
Pneumatic steel-ball locking with robot-side and tool-side interfaces. Compare dimensions and compatible adapter modules below.
Series image shown. Confirm the exact configuration against the model data below.
Price and lead time: confirmed on inquiry.
Technical specifications
Performance and interfaces
| Parameter | Value |
|---|---|
| Robot-side model | AQC-550M |
| Tool-side model | AQC-550T |
| Payload capacity | 550 kg |
| Locking force at 0.5 MPa | 38500 N |
| Static torque X/Y | 3390 N·m |
| Static torque Z | 3260 N·m |
| Outside dimension | Ø245 mm |
| Coupled height | 120 mm |
| Position repeatability | ±0.015 mm |
| Operating air pressure | 0.4–0.7 MPa |
| Locking mechanism | Steel-ball lock |
| Body material | Aluminum alloy |
| Locking mechanism material | Alloy steel |
| Ambient temperature | 0–80 °C |
| Humidity | 0–95% |
| Robot-side weight | 12.5 kg |
| Tool-side weight | 6.9 kg |
| Pneumatic ports | — |
| Maximum port pressure | 0.8 MPa |
| Angular offset | ±1° |
| Robot mounting interface | ISO 9409-1-200-6-M12 |
Compatible adapter modules
| Module | Side | Configuration | Weight | Mounting face | Connector / cable | Connector weight |
|---|---|---|---|---|---|---|
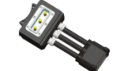 AQC-HV-03M | Robot side | 150 A; 3-pin high-current connector | 2.7 kg | B / C / D | — | — |
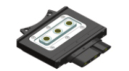 AQC-HV-03T | Tool side | 150 A; 3-pin high-current connector | 1.9 kg | B / C / D | — | — |
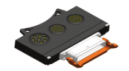 AQC-SM-A04020826M | Robot side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.2 kg | B / C / D | 10B 8+12+25 pins | 105 g |
 AQC-SM-A04020826T | Tool side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.4 kg | B / C / D | 10B 8+12+25 connector | 125 g |
 AQC-SM-K04020826M | Robot side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.1 kg | B / C / D | M23 6-pin male power / M23 12-pin male servo / 20-27P signal | 95 g |
 AQC-SM-K04020826T | Tool side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.26 kg | B / C / D | M23 6-pin female power / M23 12-pin female servo / 20-27S signal | 102 g |
 AQC-SM-Y04020826M | Robot side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.27 kg | B / C / D | 20-15P servo / 20-29P servo / 22-19P signal | 98 g |
 AQC-SM-Y04020826T | Tool side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.35 kg | B / C / D | 20-15S servo / 20-29S servo / 22-19S signal | 98 g |
 AQC-SM-F04020826M | Robot side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.3 kg | B / C / D | 20-17P servo / 20-29P servo / 20-27P signal | 102 g |
 AQC-SM-F04020826T | Tool side | 20 A × 4 current pins; 2 brake pins; 3 A × 8 encoder pins; 3 A × 26 signal pins; tool cable 1.5 m with connector | 1.32 kg | B / C / D | 20-17S servo / 20-29S servo / 20-27S signal | 105 g |
 AQC-GM08G38M | Robot side | 8 × G3/8 | 1.28 g | B / C / D | — | — |
 AQC-GM08G38T | Tool side | 8 × G3/8 | 1.14 g | B / C / D | — | — |
 AQC-LM02G12-SM | Robot side | 2 × G1/2 | 356 g | B / C / D | — | — |
 AQC-LM02G12-ST | Tool side | 2 × G1/2 | 342 g | B / C / D | — | — |
 AQC-LM04G12M | Robot side | 4 × G1/2 | 2.9 kg | B / C / D | — | — |
 AQC-LM04G12T | Tool side | 4 × G1/2 | 2.8 kg | B / C / D | — | — |
GM08G38 weights require unit confirmation before selection.
ENGINEERING RESOURCES
Technical drawings
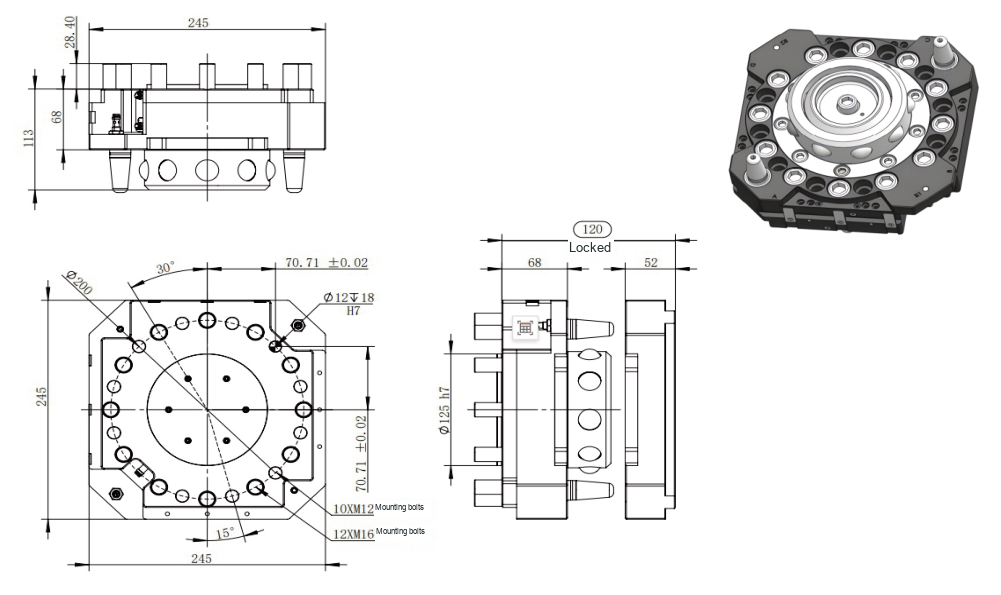
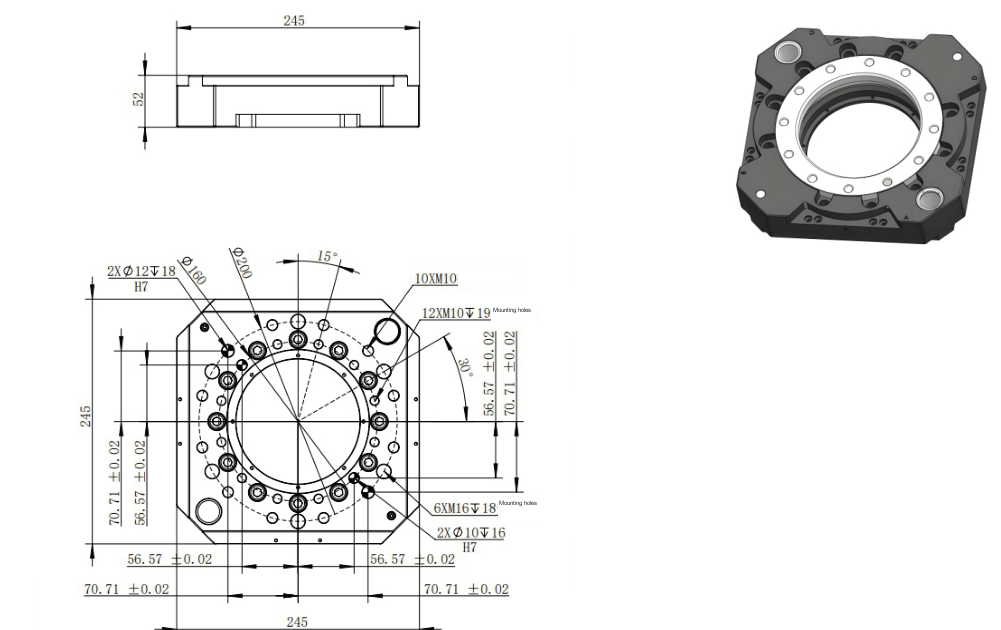
Inspect mounting holes, dimensions and interfaces. Open a drawing to zoom in or download the image.
 Enlarge drawing ↗
Robot-side dimensions
 Enlarge drawing ↗
Tool-side dimensions
Application details for your quotation
Start with the complete tooling and workpiece load, then confirm mounting dimensions, moment capacity and pneumatic connections. Confirm the applicable pulling force and ordering code for your configuration.
Read the selection guide ↗